Robotics build
Building a six-axis robot arm
An early-stage build of a 3D-printed WE-R2.4 arm, currently focused on assembling and validating the first motor-driven planetary joint.
Selected work
A growing collection of robotics, automation, programming and mechanical design work completed through coursework and independent development.
An early-stage build of a 3D-printed WE-R2.4 arm, currently focused on assembling and validating the first motor-driven planetary joint.
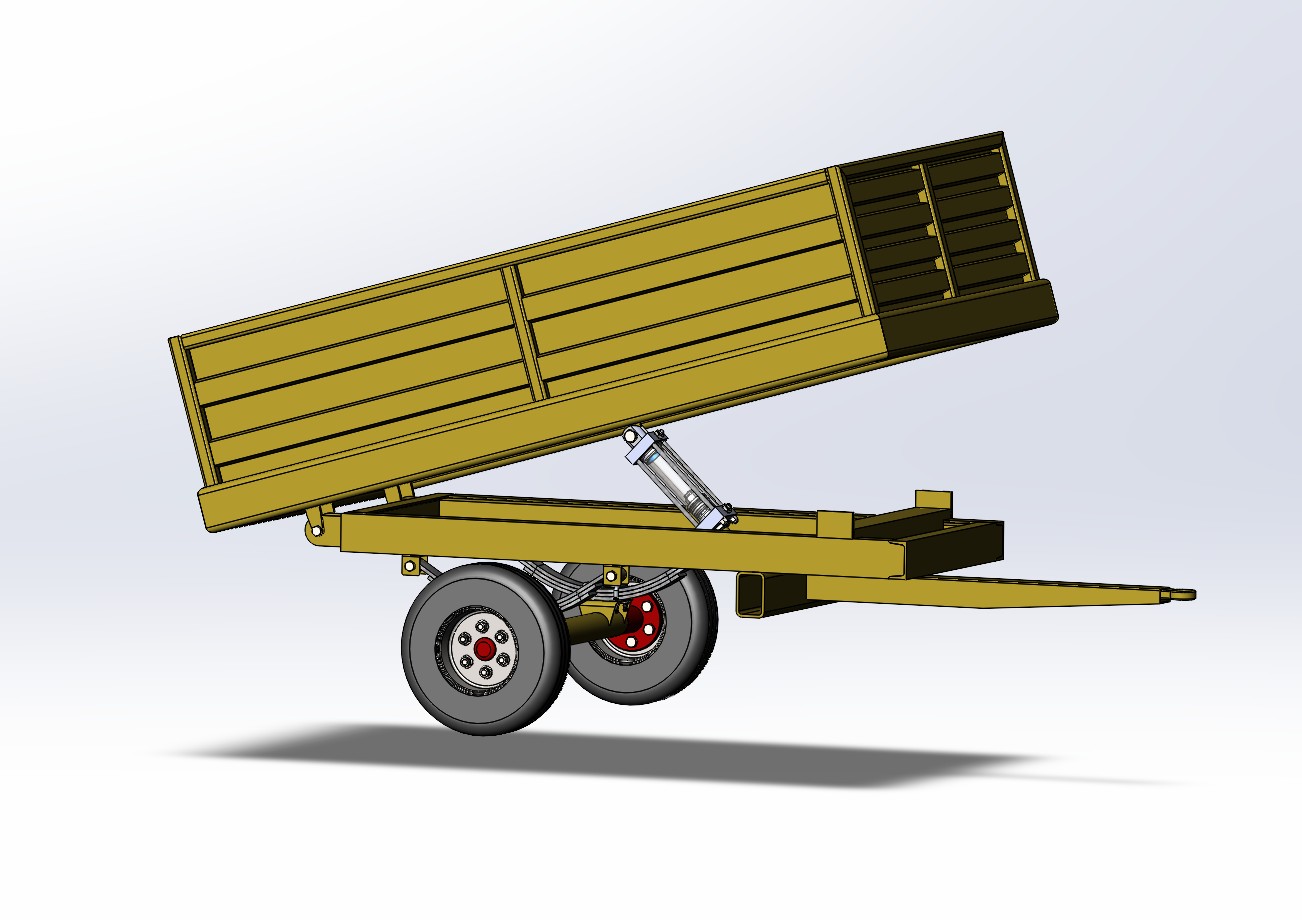
A SolidWorks course project focused on modelling, manufacturing drawings and the integration of a complete tipping mechanism.
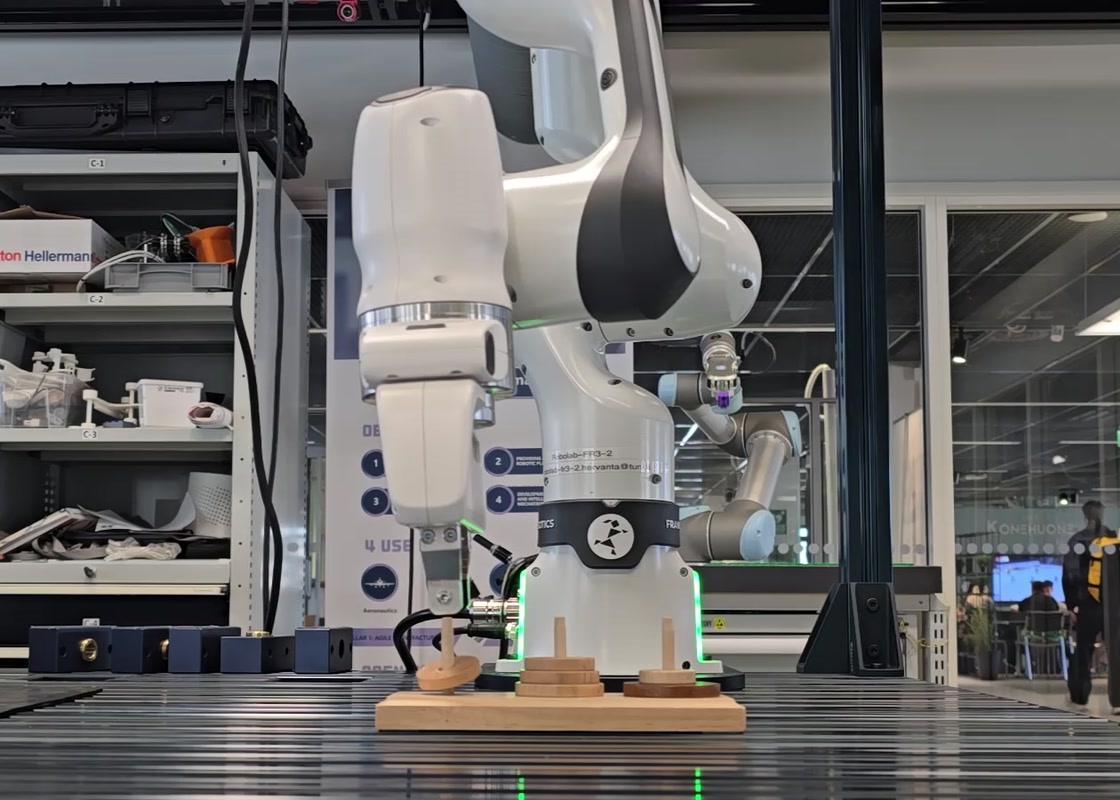
A Franka robot programmed to solve the physical puzzle using a planned move sequence and taught positions.
A case study of how I used vibe coding, iterative review and GitHub workflows to design, build and publish this portfolio.
Engineering process
I approach projects as complete systems, connecting mechanical structure, software and control instead of treating them as isolated parts.